automate · 2026 · Ongoing side lab
Robot Simulation Lab
AI robot arm in MuJoCo + ESP32 rover simulator
Robotics tinkerer · Python & JS · Personal R&D
6-DOF
Arm
MuJoCo
Physics
4WD ESP32
Rover
3× ultrasonic
Sensors
Challenge
Hardware is slow and expensive to iterate on. I wanted to prove the control logic — grasping, obstacle avoidance, navigation — in simulation before buying a single motor.
Approach
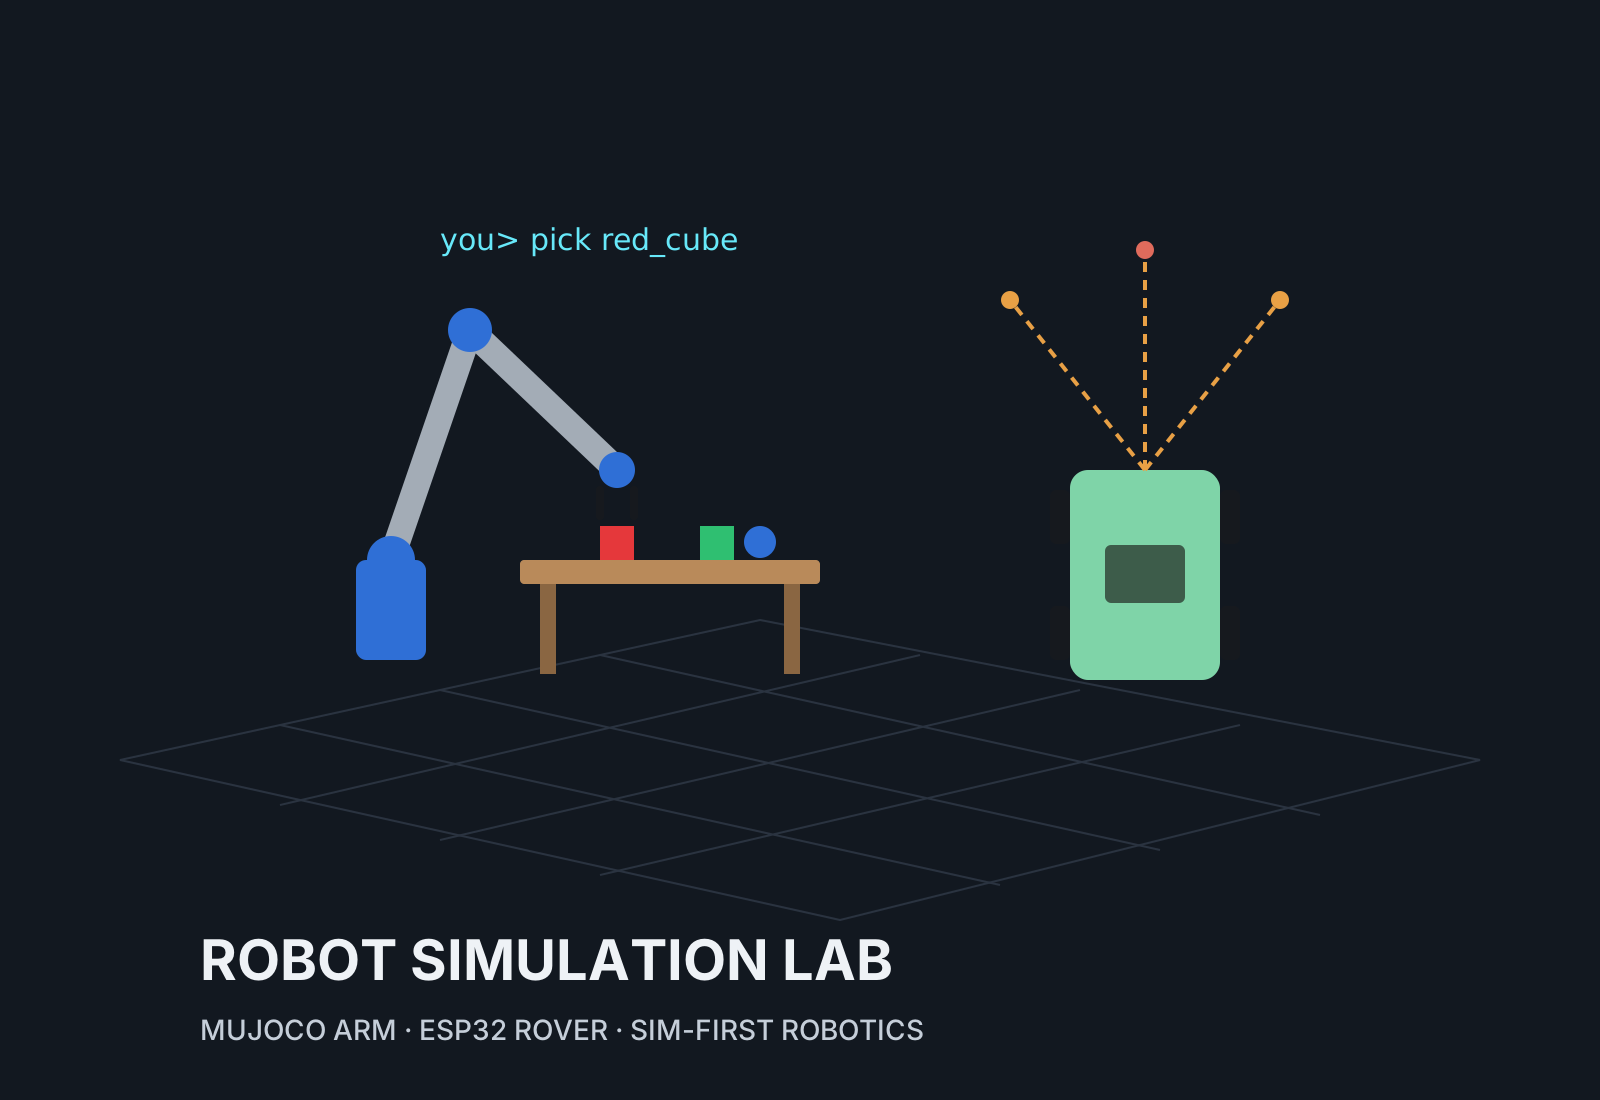
- 01AI Robot Arm: MuJoCo scene with a 6-joint arm, two-finger gripper, table and objects (red/green cubes, blue ball), plus a wrist camera.
- 02Commands in Myanmar or English go through a local LLM (Ollama) with a keyword fallback, then map to skills: pick, place_here, look_at, wave, home.
- 03Rover: browser simulator for a 4-wheel skid-steer robot that mirrors ESP32 + L298N differential drive, with front/left/right ultrasonic raycasts.
- 04Rover modes: manual, auto-wander that turns toward the more open side, and A→B grid pathfinding with live replanning; a mock server speaks the same API as the firmware.
Outcomes
- ▸Natural-language → robot skill pipeline running fully offline
- ▸Sim, phone UI, mock server and ESP32 firmware share one protocol
- ▸Hardware BOM and assembly plan ready before buying parts
The Robot Lab on the island is where I show the part of me that likes to experiment: robots building robots on the line, and two simulation bays modelled on my real projects.
The arm bay recreates my MuJoCo scene — type “pick red_cube” (or say it in Burmese) and the agent turns it into a pick-and-place skill.
The rover arena mirrors my ESP32 simulator: three ultrasonic beams, obstacle avoidance and A→B pathfinding, tested in sim before the hardware is wired.
Stack
Working on robotics, IoT or AI-driven automation? I can prototype the control loop in simulation first, then take it to hardware.